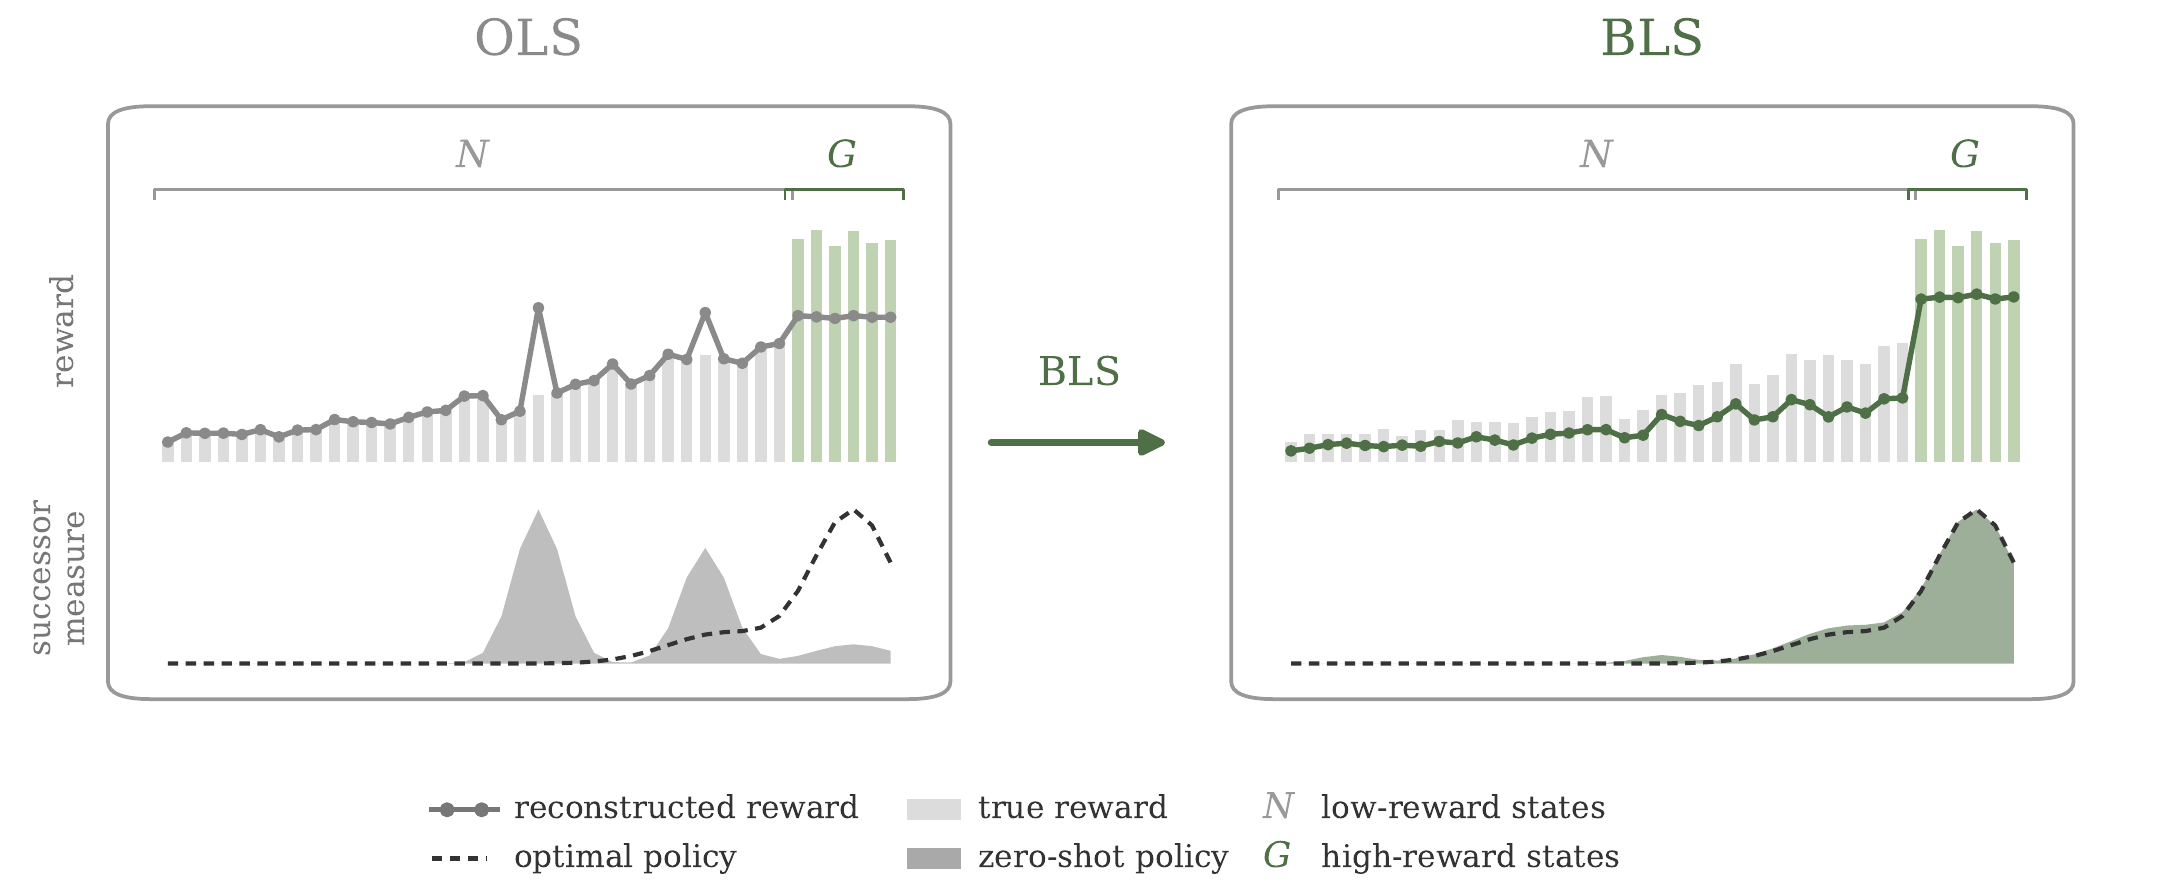
Task Inference Beyond Least Squares in Behavioral Foundation Models
NeurIPS 2026 PTA Workshop (Oral).
- Paper
- Code
- Project Website
I am a research assistant working with Prof. Tsung-Wei Ke at National Taiwan University. My research goal is to build general-purpose robots, focusing on how reinforcement learning can develop reusable physical skills for novel tasks. My research experience spans flow matching, behavioral foundation models, and dexterous robot manipulation. I also collaborate with Alberta Longhini and Tyler Ga Wei Lum in Prof. Jeannette Bohg's group (IPRL) at Stanford University. I am applying to PhD programs for Fall 2027.
NeurIPS 2026 PTA Workshop (Oral).
Under review, 2026.
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2026.
International Conference on Learning Representations (ICLR), 2026.
Under review, 2026.
Student Representative Speaker
1st Place (served as coach)
1st Place Overall Winner
2nd Place & Best AI Performance Award
1st Place Grand Jury Prize
Jul 2026 – Present
Backend and Infrastructure Developer Developed NTU COOL AI Companion
Spring 2026
TA
Spring & Fall 2025
Lead TA
Fall 2025
TA